Robot Overview
GRW is a wheeled dual-arm robot independently developed by Fourier, available in two versions: an "exterior version" and a "skeleton version." The figure below shows the standard exterior version. For detailed specifications, please refer to the《GRW Product Manual》.
Developers can use GRW for "secondary development, data collection, grasping model training, on-site debugging and deployment," and more.
Full-Machine Components
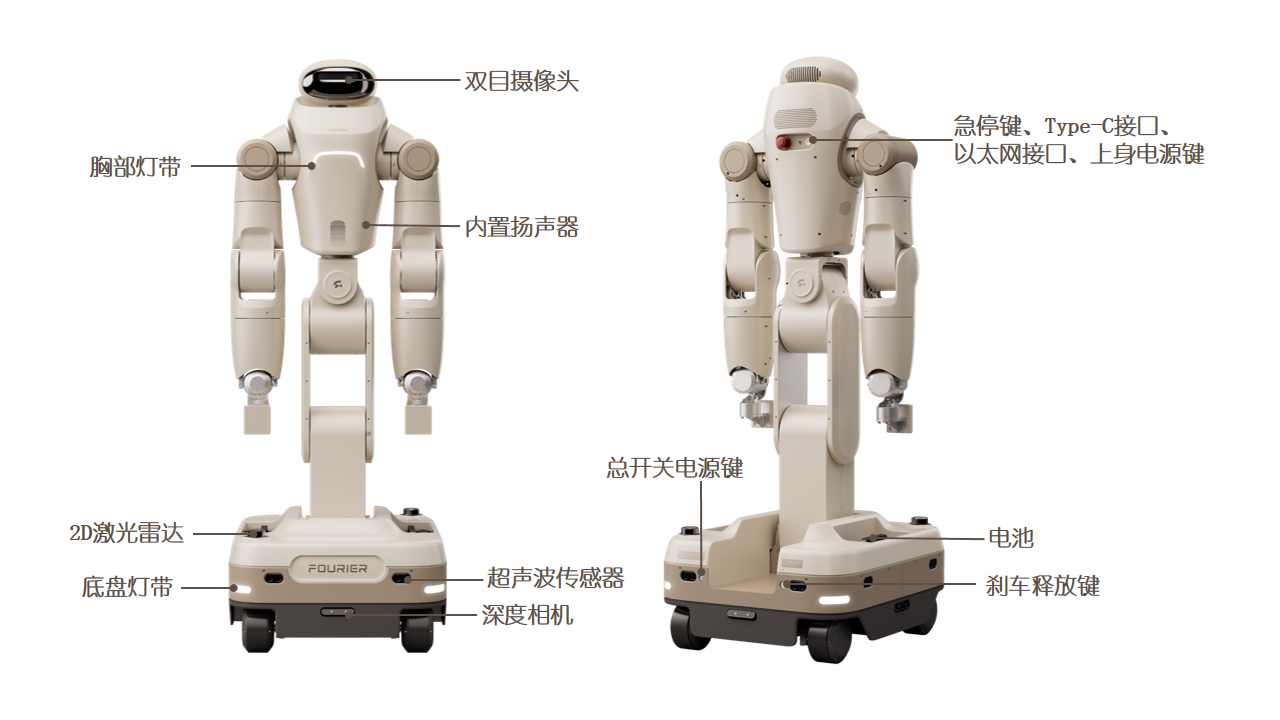
Interfaces and Buttons
| Illustration | Name | Description |
|---|---|---|
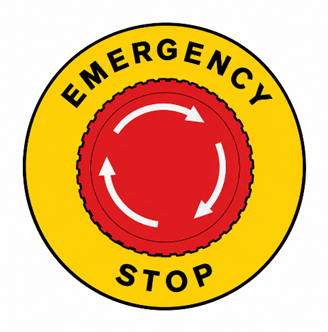 | Emergency stop button | Body emergency stop button. Press it directly in an emergency. Once pressed, the whole body stops with brakes engaged and will not fall. |
 | Type-C port | Primary debugging port; can be connected to a docking station. |
 | Ethernet port | Primary debugging port; used for Ethernet connections. |
 | Upper Body Power Button | Controls the robot's upper-body power on and off. |
 | Main power switch | Controls the main power input for the entire robot. |
 | Brake release button | The only way to push the robot manually. After power-on, press the brake release to push the robot by hand. |
Specifications
| GRW Specifications | |
|---|---|
| Mechanical Parameters | |
| Height | 1231-1695.5mm |
| Length | 722mm |
| Width | 633mm |
| Net weight | ≈240kg |
| Shoulder width | 584mm |
| Arm span | 1966mm (excluding end-effector) |
| Max reach height | 2143.7mm |
| Turning diameter | 880mm |
| Joint Parameters | |
| Total DOF | 24 (excluding end-effector) |
| Head DOF | 2 |
| Single-arm DOF | 7 |
| Waist DOF | 3 |
| Leg DOF (folding section) | 2 |
| Chassis DOF | 3 |
| Max joint peak torque | 500 N·m |
| Communication interface | EtherCAT |
| Electrical Parameters | |
| Nominal voltage | 44.8V |
| Rated power | ≈1300W |
| Fail-safe brake | Equipped (except chassis) |
| Performance Parameters | |
| Average travel speed | ≈0.8m/s |
| Max slope | ≤10° |
| Base compute | AMD Ryzen 8-core high-performance CPU |
| High-compute module | Optional backpack: Jetson-AGX-Orin / Thor |
| Dual-arm rated payload | 16 kg |
| Repeat positioning accuracy | ±0.1 mm |
| Battery & Adapter | |
| Battery capacity | Dual batteries, 672Wh each |
| Battery type | Lithium-ion battery |
| Single battery weight | 6.1kg |
| Battery nominal voltage | 44.8V |
| Charging voltage limit | 51.1V |
| Cycle life | ≥2000 (80% DoD) |
| Runtime | 4h |
| Charging time | ≈2h (0~80%) |
| Adapter input | 100~240V AC, 50/60Hz |
| Adapter output | 51.1V DC 7.0A |
| Hot-swappable | Supported |
| CPU | |
| Operating system | Ubuntu 22.04 |
| Processor | AMD Ryzen |
| I/O | Type-C (USB3.0), RJ45 |
| Perception Sensor Configuration | |
| Camera module | Head: RGB + structured-light depth camera × 1 |
| Chassis: depth camera × 4 | |
| Radar module | Chassis: ultrasonic radar × 8 |
| Chassis: LiDAR × 2 | |
| IMU | 6-axis, supports acceleration and angular velocity detection |
| Speaker | Equipped |
| Shell Material | |
| Shell material | Aviation aluminum + engineering materials |
| End-effector module | No end-effector in the base version. Parallel gripper, two-finger, three-finger, or five-finger dexterous hand available as options |
Joint Limits
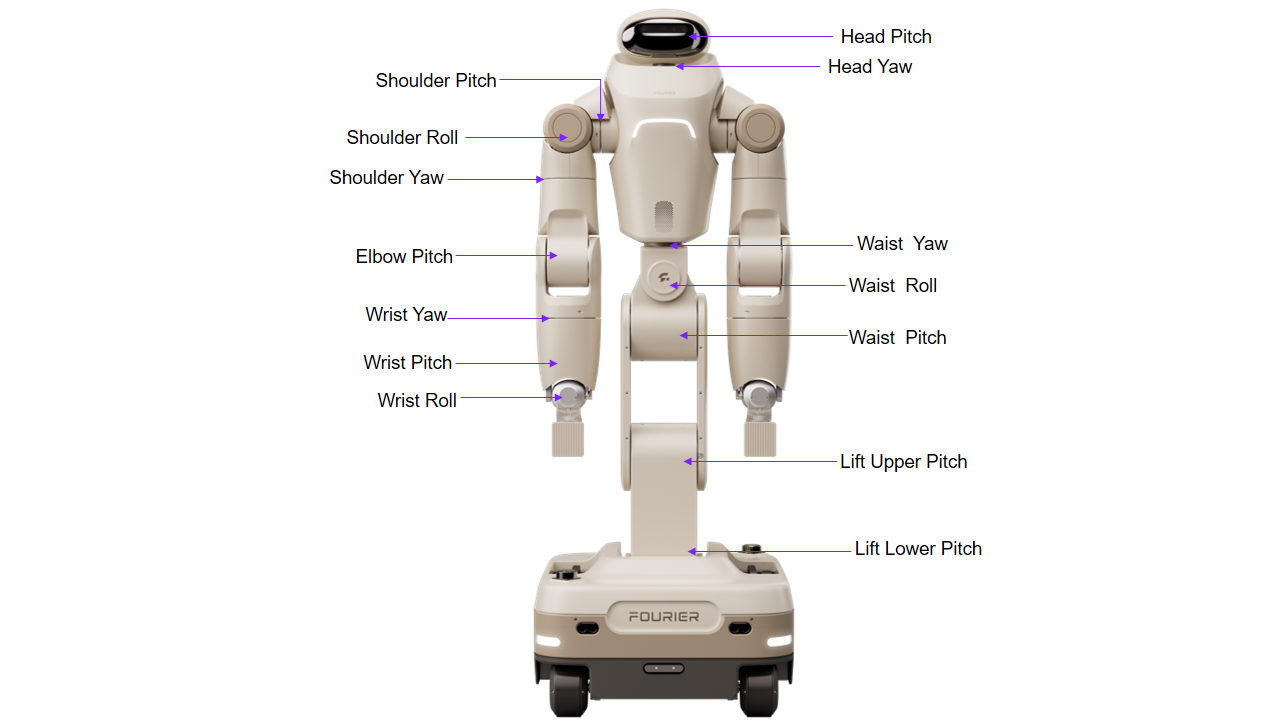
| Body Part | Joint Name | Range of Motion |
|---|---|---|
| Head | Head Pitch | -30°~30° |
| Head Yaw | -80°~80° | |
| Shoulder | Shoulder Pitch | -170°~170° |
| Shoulder Roll | R: -110°~15° / L: -15°~110° | |
| Shoulder Yaw | -105°~105° | |
| Elbow | Elbow Pitch | -100°~35° |
| Wrist | Wrist Yaw | -105°~105° |
| Wrist Pitch | -75°~75° | |
| Wrist Roll | -70°~70° | |
| Waist | Waist Yaw | -150°~150° |
| Waist Roll | -45°~45° | |
| Waist Pitch | -60°~14° | |
| Knee | Lift Upper Pitch | -90°~58° |
| Ankle | Lift Lower Pitch | -29°~45° |
Actuator IP Distribution
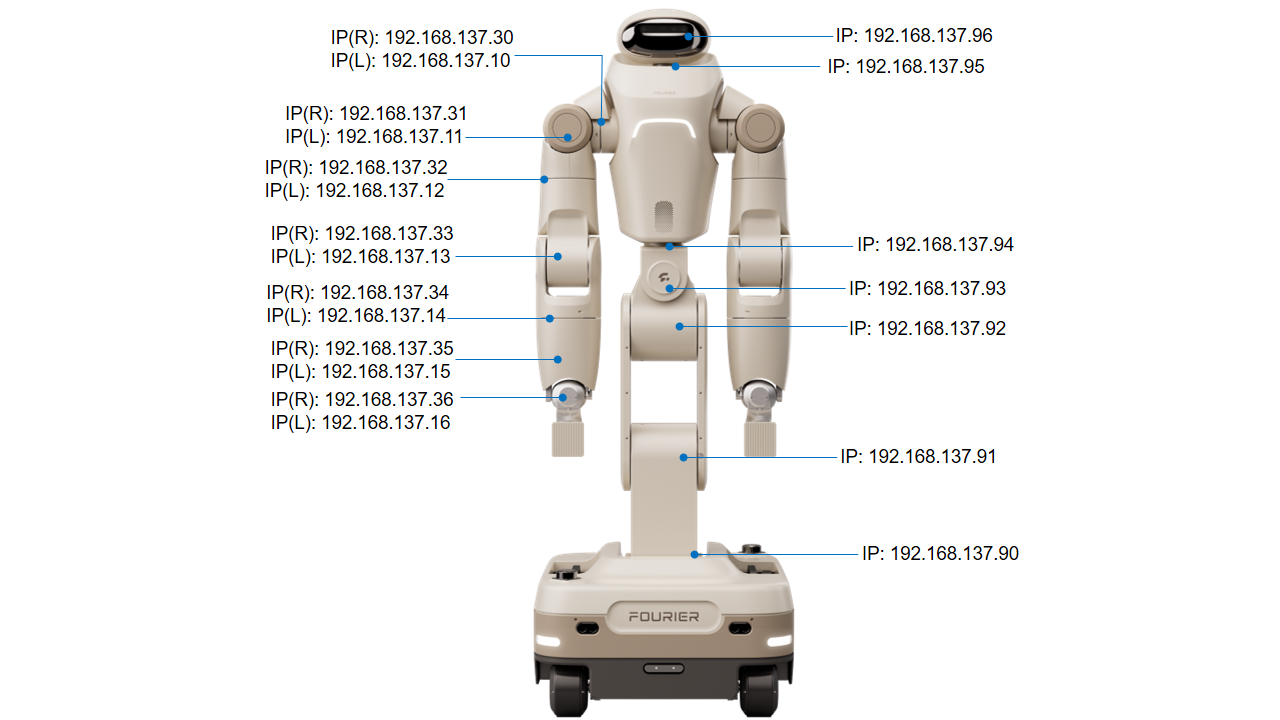
Sensor Field of View
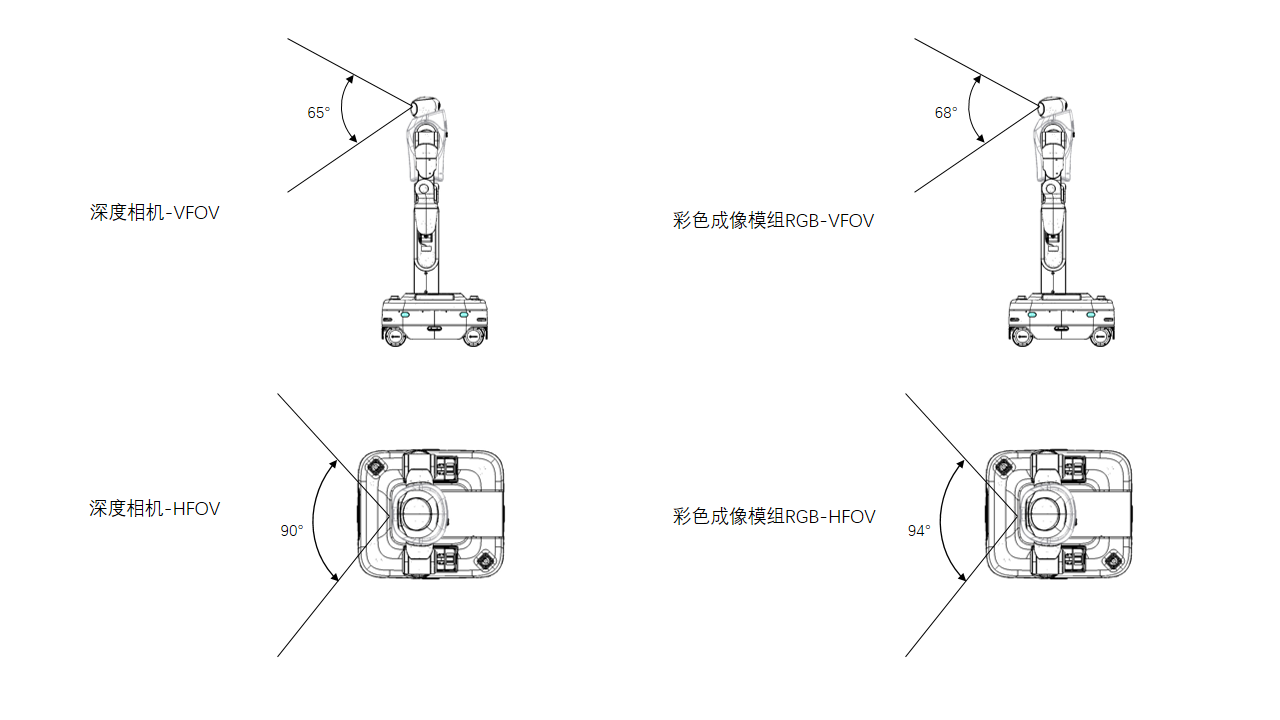
Head camera field of view